Length Matching in High Speed Buses

Length Matching in High Speed Buses

GSAS Engineering · · 1 min read

Length Matching in High Speed Buses.

With ever increasing speeds in high speed data systems comes a couple of PCB layout challenges. High speed busses like DDR, VME, PCIe just to mention a few can all reach data transfer speeds that require strict timing with very tight tolerances, thereby leaving very little slack in the PCB layout.

Join us in this webinar to learn why it’s imperative to match track lengths in high speed data systems and differential signals. You’ll see how to properly define PCB length matching and time delay constraints, and how to effectively route high speed signals in Altium Designer®.

Timing:

Thursday, 26th November 2020 | 02:30 PM to 03:30 PM

Here are just some key points you can expect to walk away with:

  • Why is it important to match track lengths in high speed signals?
  • Length matching and time delay tuning in high speed buses and differential signals
  • How to set up high speed PCB constraint rules from the schematics or PCB.
  • How to tune single ended and differential tracks.

Event CompletedLEARN MORE ABOUT Altium Tools

Recorded webinar

Interested in Siemens EDA tools?

Talk to our application engineers for personalized tool recommendations.

Stay in the Loop

Get monthly compliance updates, product insights, and engineering best practices delivered to your inbox.

Related Articles

Embedded engineering bench in India, illustrating the hardware a developer can act on today, supported by GSAS
Technical Guides Arm

Arm's Agentic AI Push: What Indian Embedded Teams Can Actually Use Today

Arm has set out its platform strategy for the agentic era, putting inference everywhere it has compute. Indian embedded teams can start on that direction this quarter with the Cortex-M toolchain they already own: Helium, CMSIS-NN, Ethos-U and Vela, on boards you can order today.

13 Sept 2026 · 7 min read
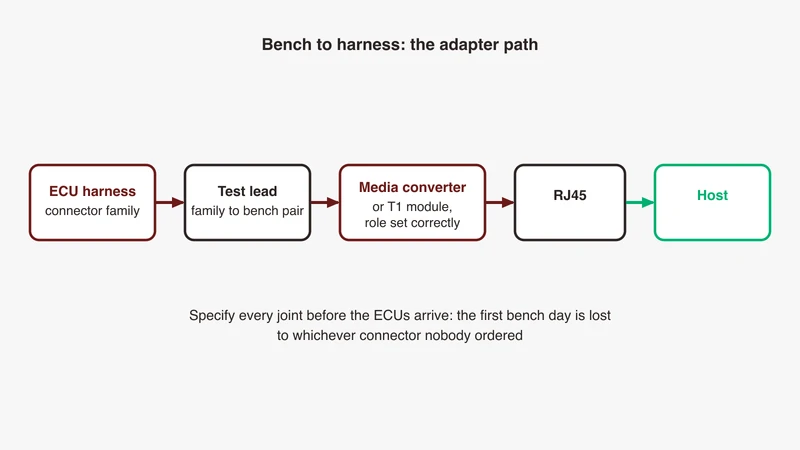
The bench to harness adapter path drawn left to right: the ECU connector, a test lead, a media converter or pluggable T1 module, RJ45, and the host, showing where each connector family sits between the device under test and the laptop, from GSAS Micro Systems India
Automotive Ethernet Automotive & Mobility

Automotive Ethernet Connectors: H-MTD, MATEnet, MQS

An ECU arrives on the bench with a connector nobody has a mate for, and the day is gone. Search the family names and you get connector product pages that describe their own part and stop there. This article puts the families side by side in one table using only what their public pages state, then makes the point those pages leave out: the IEEE link segment definition, not the connector, is what sets reach and loss limits, and shielding is a channel decision rather than a preference. Written by the GSAS Micro Systems engineering team in India.

29 Aug 2026 · 12 min read
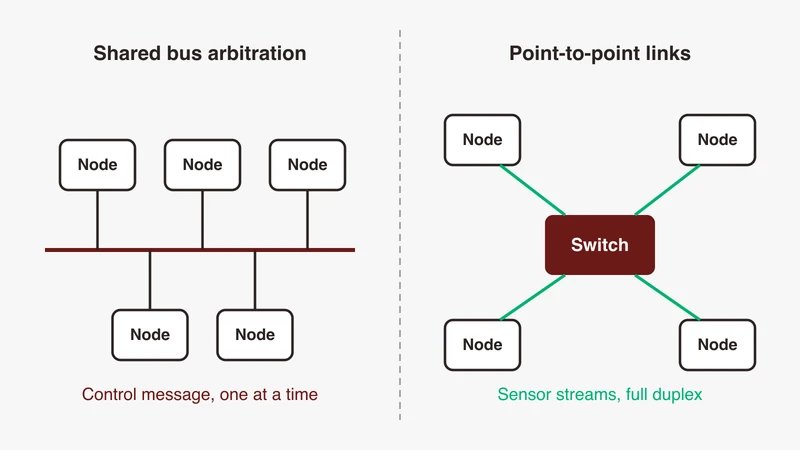
Split panel diagram comparing one control message on a shared multidrop CAN bus with one sensor stream on a switched point to point Ethernet link, labelled shared bus arbitration, node, point to point link, switch, control message and sensor stream, from GSAS Micro Systems India
Automotive Ethernet Automotive & Mobility

CAN vs Automotive Ethernet: When to Use Each

CAN and automotive Ethernet answer different questions, so the useful comparison is a decision table rather than a winner. This guide from GSAS Micro Systems sets CAN and CAN FD figures from CAN in Automation next to the IEEE 802.3bw objectives for 100BASE-T1, covers arbitration against switch queues, cost and harness consequences, failure modes on both sides, and what changes on an India bench team's setup when a project adds Ethernet next to the CAN it already runs.

29 Aug 2026 · 14 min read